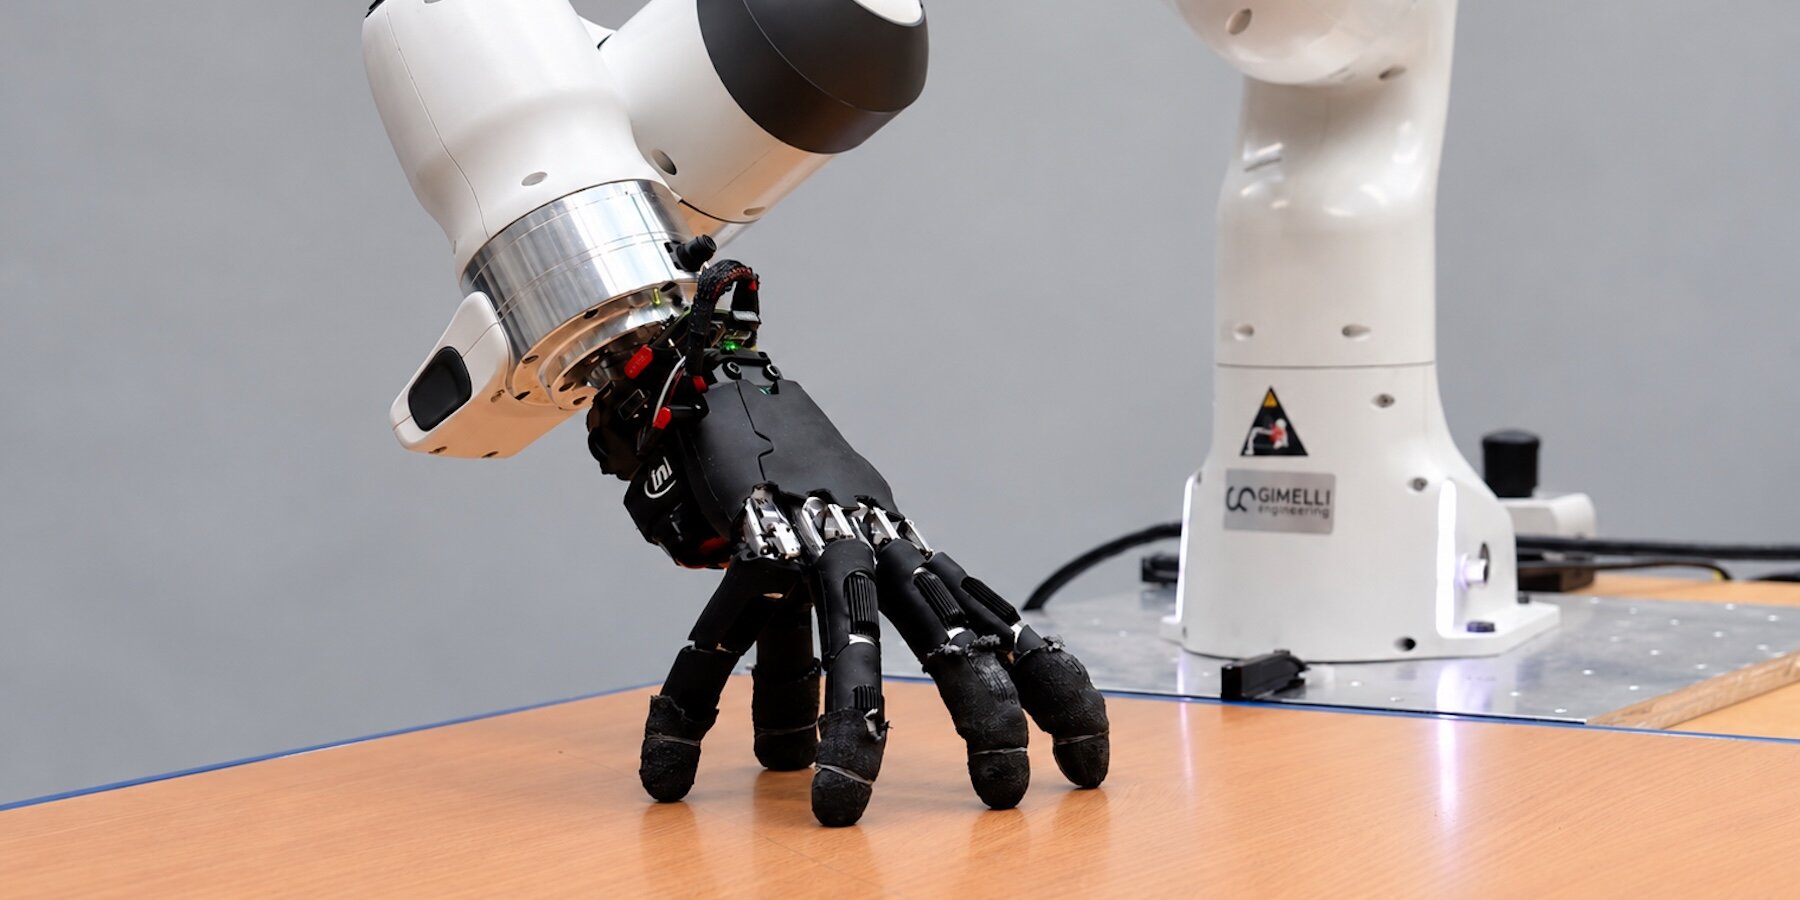
ETH ZURICH TRAINS ROBOTIC HAND TO WALK ON ITS FINGERS
A robotic hand has apparently decided it no longer needs the rest of the robot. Researchers at ETH Zurich’s Soft Robotics Lab have developed an autonomous five-fingered hand that can walk across different surfaces, steer itself, recover after falling over and interact with objects — all using the same fingers normally reserved for grasping. Rather than adding wheels or legs to the system, the team turns the hand itself into a mobile robot, allowing its fingers to alternate between supporting, moving and manipulating its body.
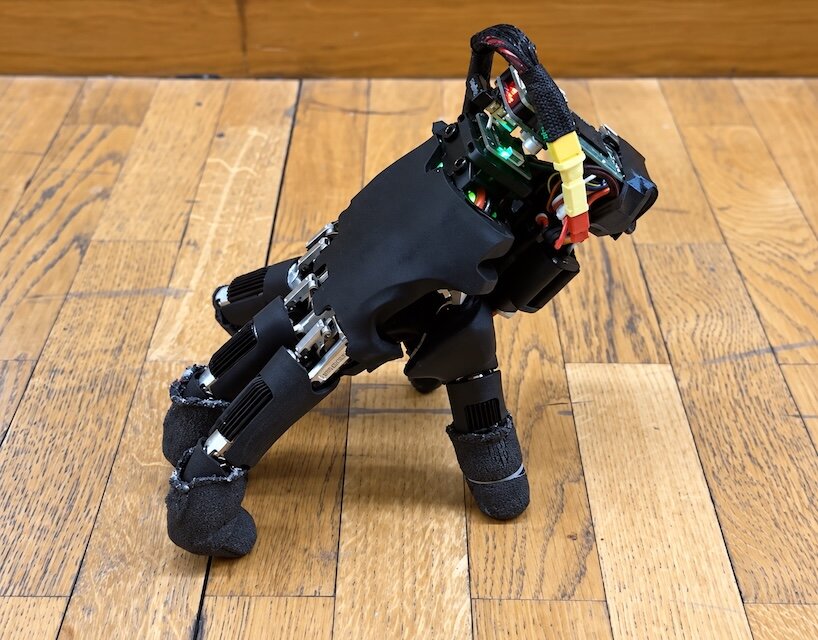
The prototype is based on a commercially available anthropomorphic hand equipped with five fingers and 20 actuated joints, four for each finger. Researchers Amirhossein Kazemipour, Hehui Zheng and Robert K. Katzschmann added a compact onboard system containing a battery, sensors and computing hardware, bringing the complete untethered robot to 818 grams. The resulting machine needs no external arm to carry it around and, despite looking suspiciously ready for a role in The Addams Family, is intended as a practical experiment in mobile manipulation.
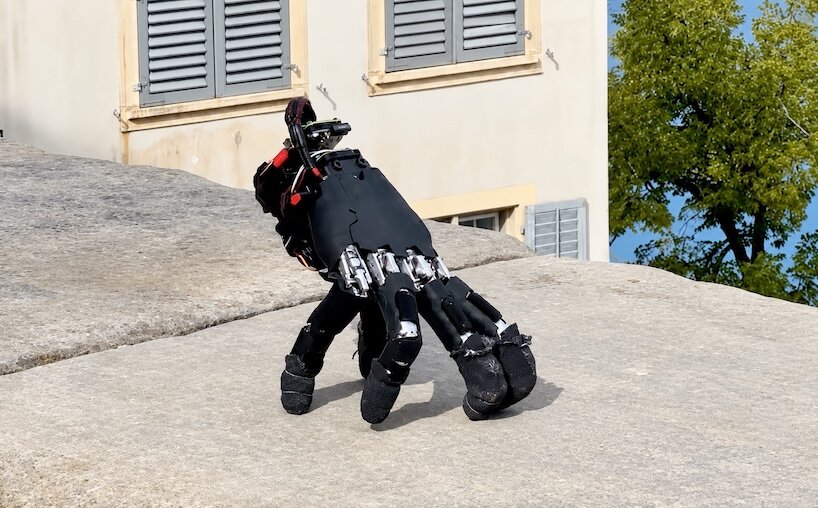
the robotic hand walks using its five fingers | all images courtesy of ETH Zurich
REINFORCEMENT LEARNING PUTS FIVE FINGERS TO WORK
Teaching a hand to walk is slightly more complicated than asking it to behave like a very small quadruped. Unlike legs, its five fingers have different geometries and ranges of motion, while the palm naturally sits at an angle. When one finger leaves the ground to take a step or interact with something, the others must continue balancing the robot’s entire weight. The researchers addressed this asymmetry through reinforcement learning, training locomotion policies in simulation before transferring them to the physical hand.
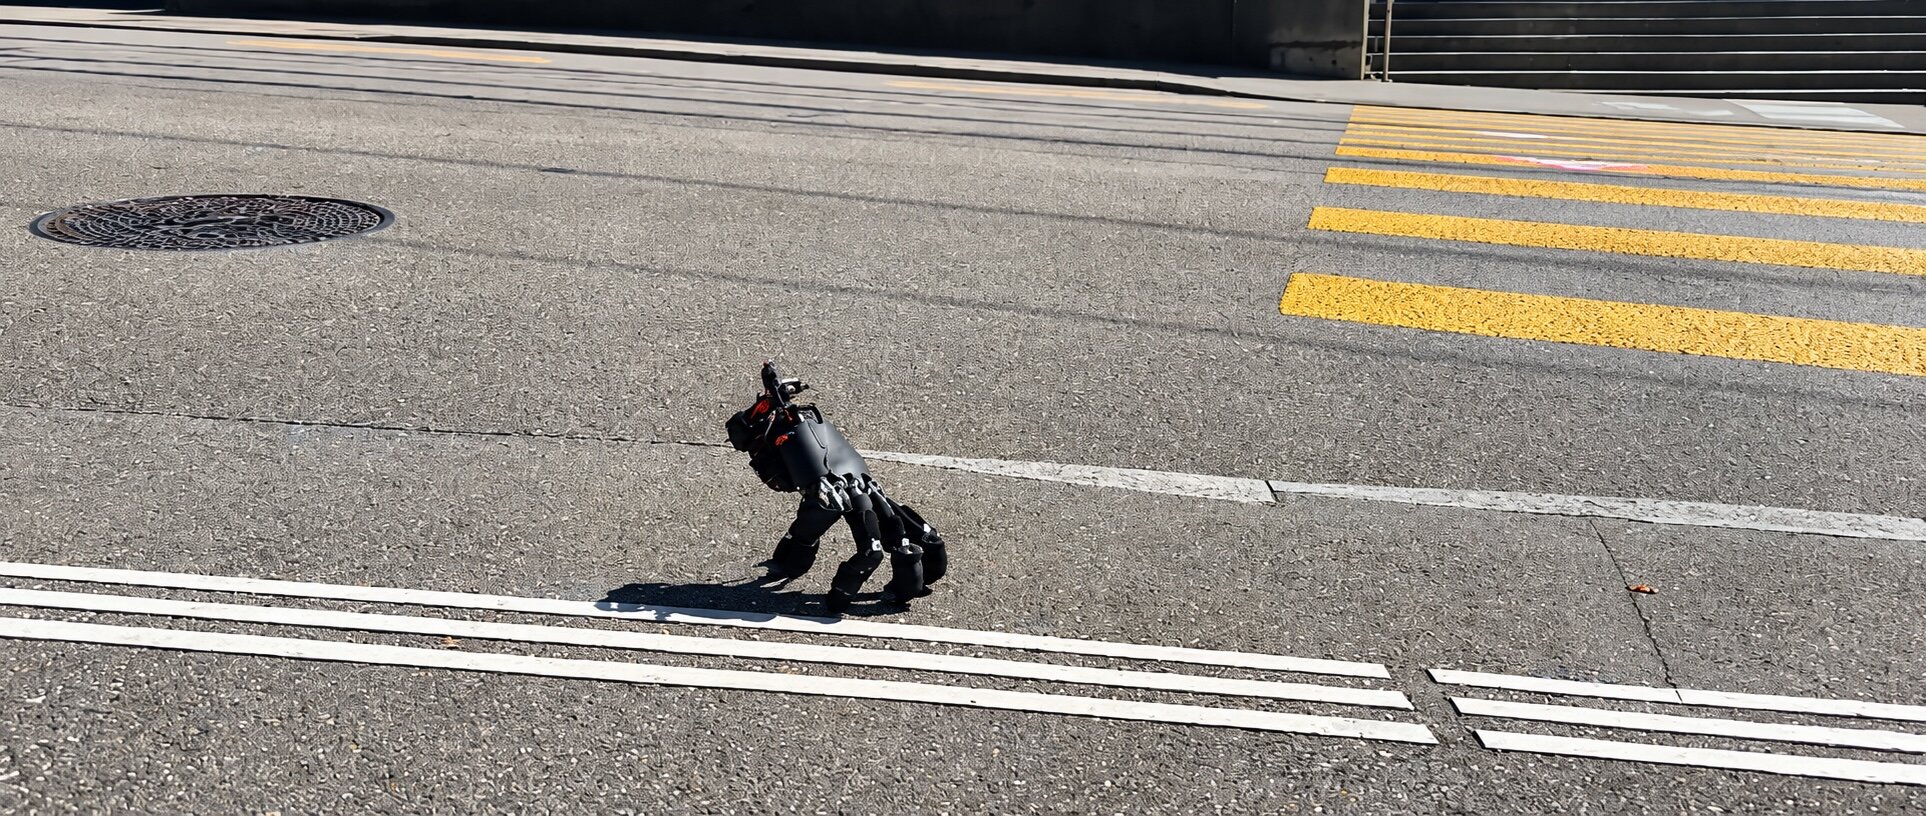
The results take the robot well beyond a tabletop demonstration. ETH Zurich’s hand was able to move untethered across 14 indoor and outdoor surfaces, including carpet, tile, metal grating, asphalt, grass, gravel and weathered stone. When deliberately placed on its side, it successfully pushed itself back upright in 21 of 25 trials. Its fingers can also switch from locomotion to manipulation: in one experiment, the robot supported itself while pressing keyboard arrow keys, correctly hitting 29 out of 32 targets. It then put those keyboard skills to excellent use by completing moves in the puzzle game Sokoban.
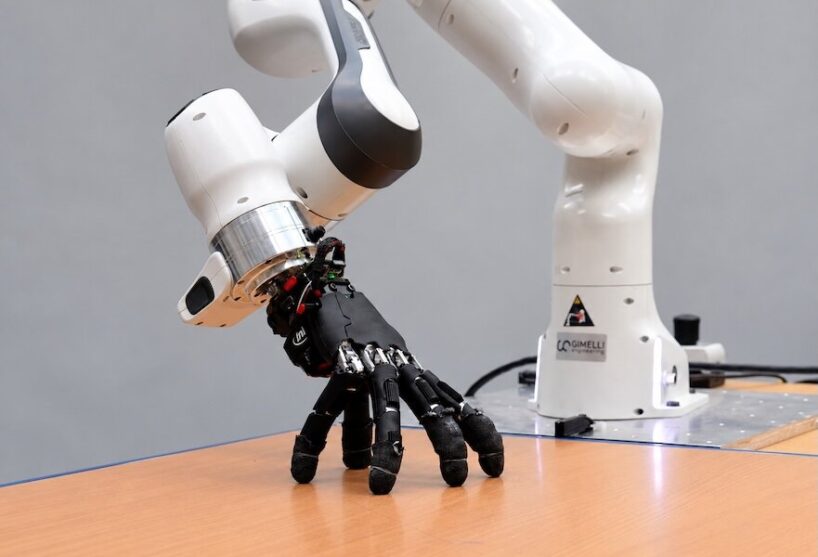
the autonomous system weighs 818 grams
AUTONOMOUS ROBOTIC HAND BECOMES ITS OWN MOBILE MANIPULATOR
Other experiments asked the hand to approach and push a small object toward a target, demonstrating how locomotion and manipulation can operate as part of the same system. This dual role is central to the research. Conventional robotic hands generally arrive at a task attached to an arm, which itself may need a larger mobile platform to move through space. Giving the end effector its own means of locomotion removes some of that hardware and could allow a larger robot to leave its hand close to an otherwise inaccessible area.
The researchers imagine a future system in which a robot places the hand near a narrow opening or confined workspace, letting it crawl independently toward a control or object, perform the required task and return to be collected. Further development will require better onboard perception and a broader range of movement, but the experiment already reframes a familiar piece of robotic anatomy: instead of designing another mechanism to carry the hand where it needs to go, ETH Zurich simply taught the fingers to take it there.
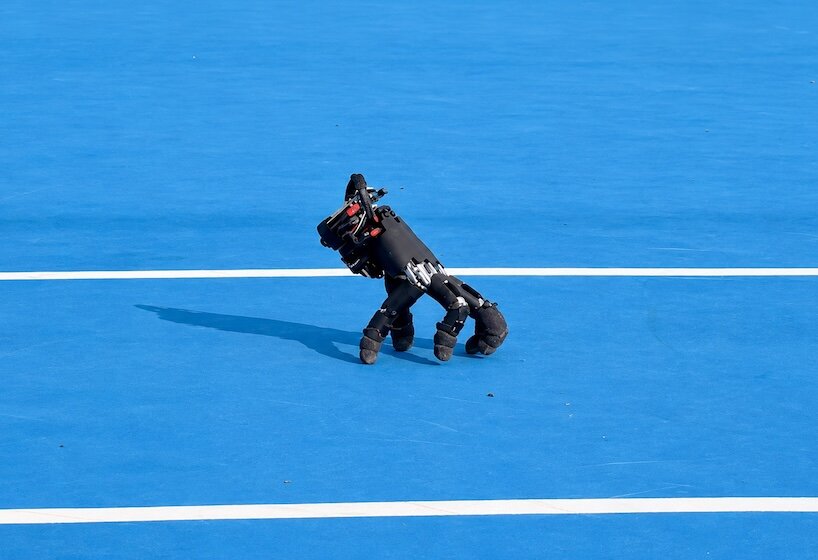
all five fingers double as legs
20 actuated joints control the hand’s movement
the hand navigates indoor and outdoor surfaces
project info:
name: Fingers as legs, Anthropomorphic hand
design: Amirhossein Kazemipour, Hehui Zheng, Robert K. Katzschmann
location: Soft Robotics Lab, ETH Zurich
happening now! effe and patricia urquiola design baluar, a sauna and hammam collection translating medieval bastion geometries into wellness architecture.
artificial intelligence (532)

ETH zurich (52)
 Aug 26, 2025
 Jul 01, 2025
 Jun 21, 2025
 Jun 01, 2025
 May 21, 2025
robots (617)


 Sep 08, 2026
 Sep 01, 2026
